
The cleanroom technology laboratory provides specialised infrastructure and facilities for researching processes under controlled environmental conditions and to the highest purity standards, and for teaching these subjects.
The courses and research projects provide knowledge on contamination control, particle measurement technology, as well as high-purity automation and automated material flow in the semiconductor industry.
The following areas and systems are available for the investigation and testing of cleanroom processes:
The laboratory’s infrastructure is based on two separate cleanroom areas. These enable processes to be carried out under strictly controlled environmental conditions and with minimal particle concentration.
ISO class 8 cleanroom
- cleanroom in accordance with ISO 14644-1 Class 8
- approx. 80 m² test area
- airlock and changing area for the correct entry of personnel and materials
- conducting fundamental tests on airflow and particle measurement
- preparation zone for processes with higher cleanliness requirements
- used in particular for the assembly of equipment in research projects
ISO class 3 cleanroom
- cleanroom in accordance with ISO 14644-1 Class 3 (highest level of particle control)
- room size approx. 20 m²
- laminar flow technology for controlled, low-turbulence displacement flow
- enables the performance of highly sensitive handling processes in semiconductor technology and microelectronics
- used for measuring particle emissions and cleanroom validations
2x TSI AeroTrak particle counters
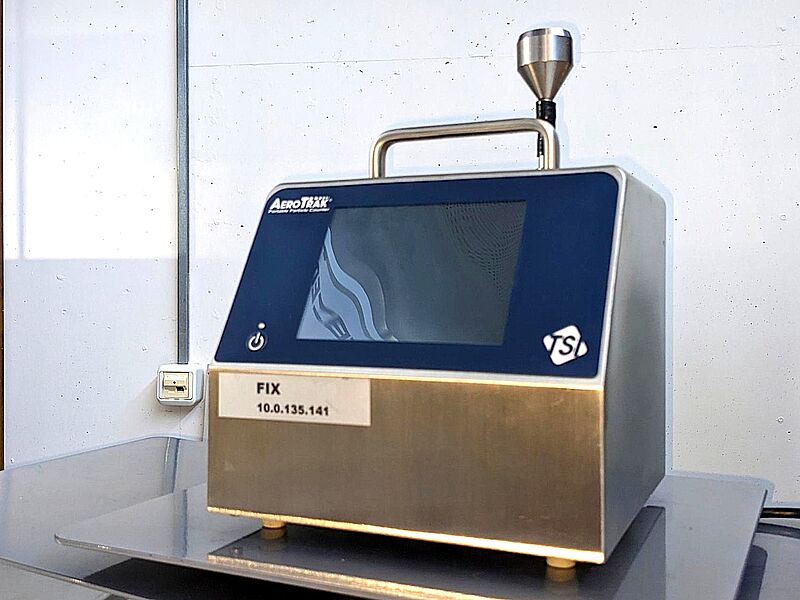
- portable optical particle counters for the precise classification and monitoring of cleanrooms
- multi-channel measurement of various particle sizes (e.g. from 0.3 µm and 0.5 µm) in accordance with ISO 14644-1
- high flow rate and integrated data storage for validation and monitoring tasks in laboratory settings
State-of-the-art demonstrators and autonomous transport systems are available for research and teaching in the field of automated manufacturing under cleanroom conditions.
KUKA KMR iiwa 14
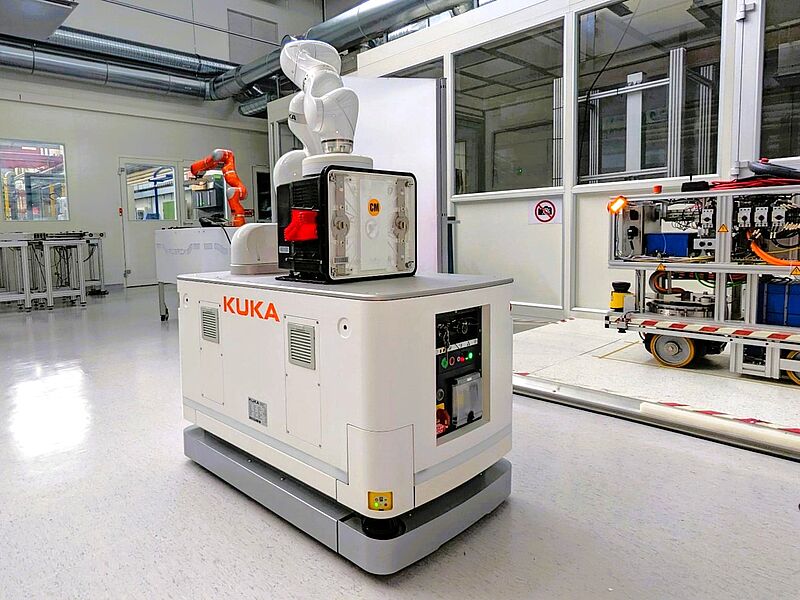
- autonomous, mobile robot system (KUKA Mobile Robotics)
- combination of a driverless transport system and a collaborative lightweight robot (LBR iiwa 14 R820)
- robot arm with 7 axes and integrated torque sensors in all joints
- rated payload (robot arm): 14 kg
- reach (robot arm): 820 mm (0.82 m)
- mobility platform with omnidirectional drive (Mecanum wheels) for maximum manoeuvrability in confined spaces
- laser scanner-based, autonomous navigation (SLAM) for safe obstacle avoidance in cleanroom environments
- integrated system control (KUKA Sunrise Cabinet in combination with KUKA Navigation Solution) for seamless control of the arm and platform
- end-effector: Passive gripper, specially designed for the safe handling and transport of FOUPs
Roller conveyor system for FOUPs
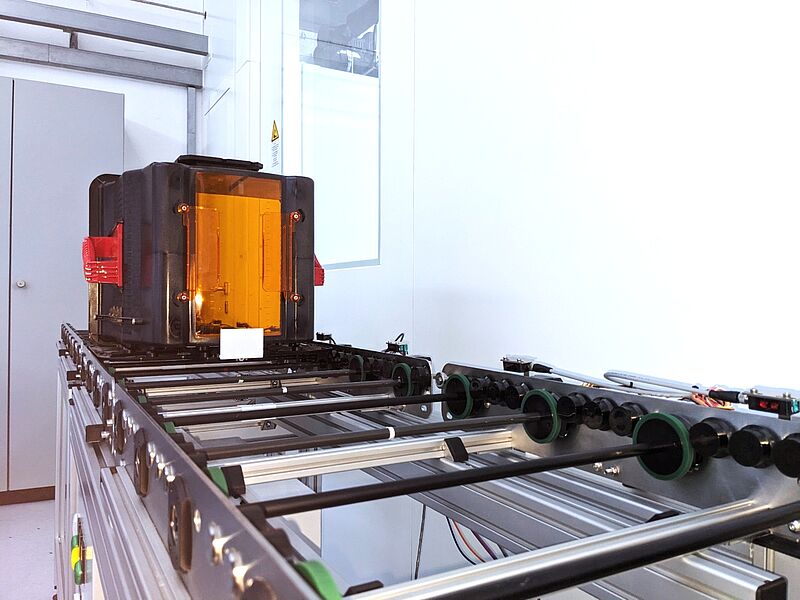
- system for the automated transport of FOUPs (Front Opening Unified Pods) for 300 mm wafers
- investigation of Industry 4.0 concepts and interfaces between stationary conveyor systems and mobile robots, bearing damage detection and predictive maintenance
- research demonstrator from the European AIMS5.0 project (Artificial Intelligence in Manufacturing Systems)

Location-flexible and self-sufficient robot module
- KUKA LBR 4+
- 7-axis robotic arm
- rated payload: 7 kg
- reach: approx. 0.8 m
- repeatability: ±0.05 mm
- compact, sensitive, lightweight cobot for flexible use on mobile units
- integrated torque sensors in all axes for safe human-robot collaboration and precise joining in cleanroom environments
- battery-powered, self-sufficient power supply unit for location-independent cleanroom and assembly applications with an integrated battery (gross capacity of 1,200 Wh)